Preprint, 2026
SimuScene: Simulation-Ready Compositional 3D Scene Reconstruction from a Single Image
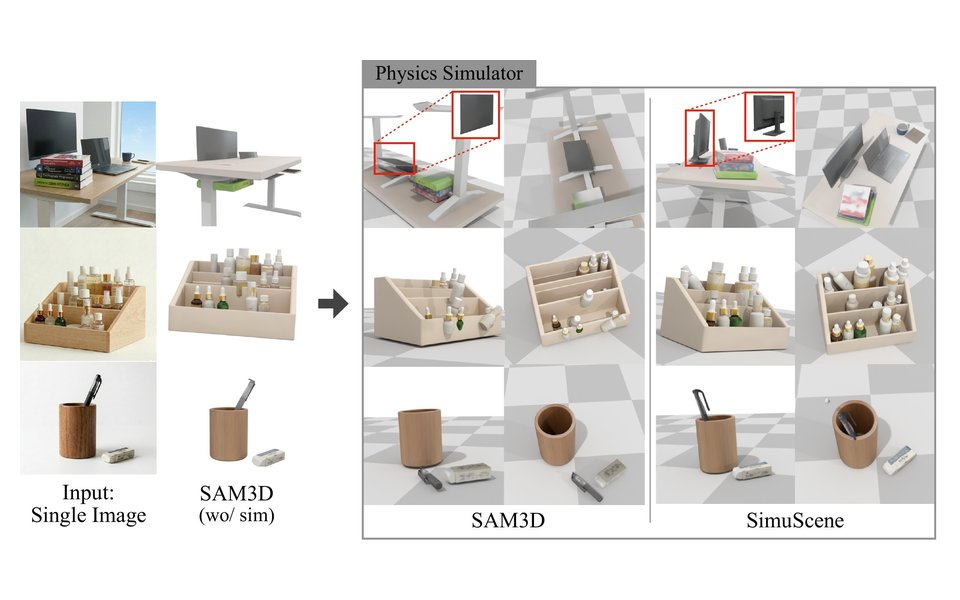
Reconstructs interactive, simulation-ready 3D scenes from a single image by putting a physics engine in the loop of shape and layout estimation.
I'm an undergraduate researcher at Seoul National University, advised by Prof. Hanbyul Joo. I work on robot learning where 3D perception meets manipulation: teaching robots to understand the scenes they act in. Previously, I worked with Prof. Songhwai Oh at the Robot Learning Lab.
My long-term goal is to build robots that act in the open world as fluidly as people do: seeing a scene in 3D, reasoning about what to do, and carrying out long-horizon, dexterous behavior reliably. Toward this, I work on turning what a robot sees into simulation-ready worlds, grounding language in 3D for manipulation, and generative planners fast enough to run inside the control loop.
Preprint, 2026
Reconstructs interactive, simulation-ready 3D scenes from a single image by putting a physics engine in the loop of shape and layout estimation.
Preprint, 2026
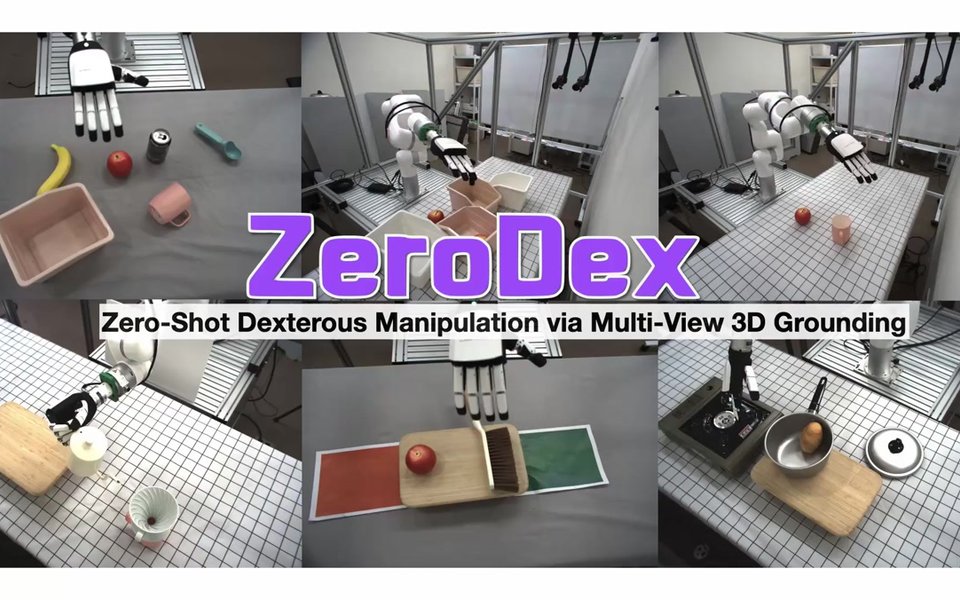
Grounds language instructions into executable 3D task plans from multi-view RGB images, enabling zero-shot long-horizon dexterous manipulation and tool use.
* Equal contribution
Research, 2025
Real-time milestone replanning for long-horizon manipulation, using one-step Mean Flow sampling inside a hierarchical planner.
Research, 2025
Swapping diffusion for flow matching in Diffuser to cut sampling steps for real-time control, plus re-parameterization and advantage guidance.
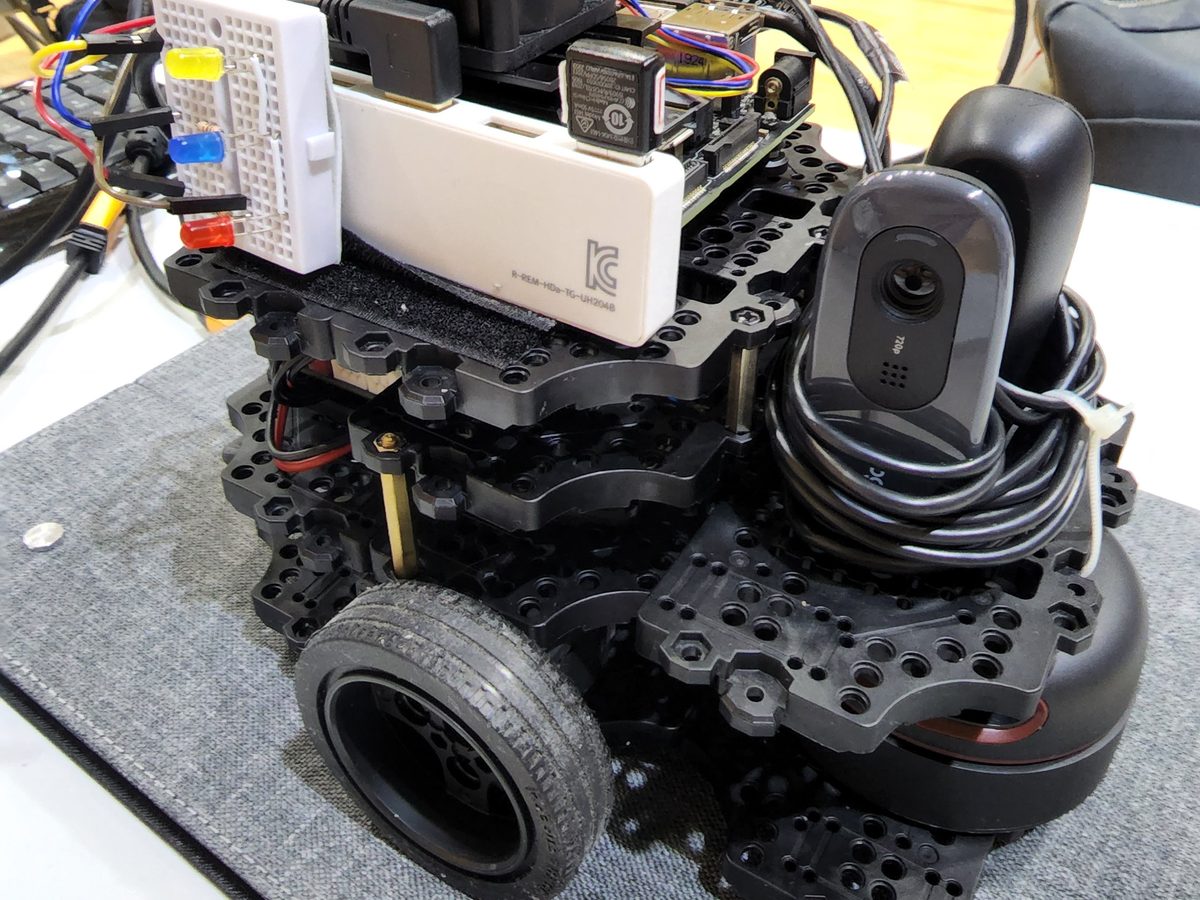
Robotics Grand Prize
A low-cost ROS robot that navigates GPS-denied orchard rows and maps healthy and diseased fruit in real time.
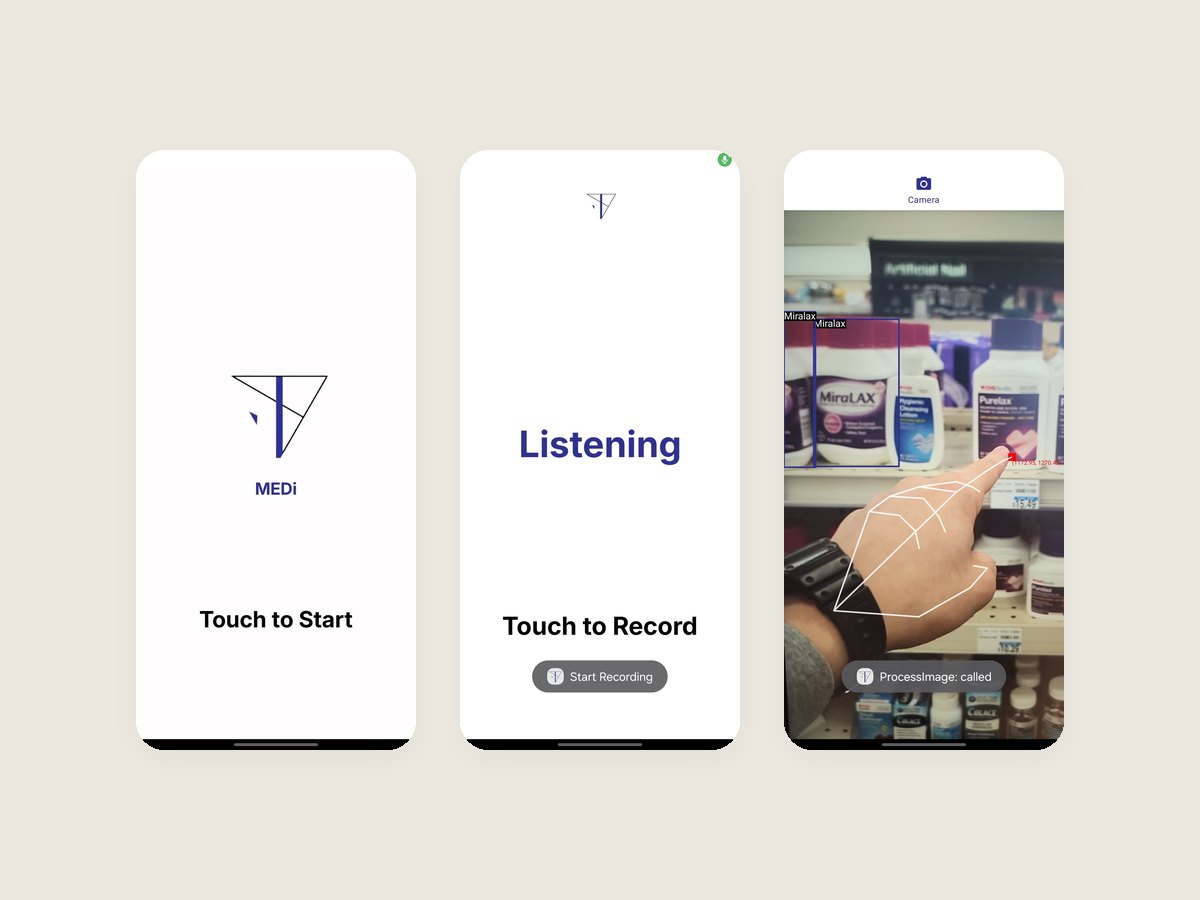
Product, 2025
An Android assistant that helps blind and low-vision shoppers find the right medicine. Point at a product and hear what it is.
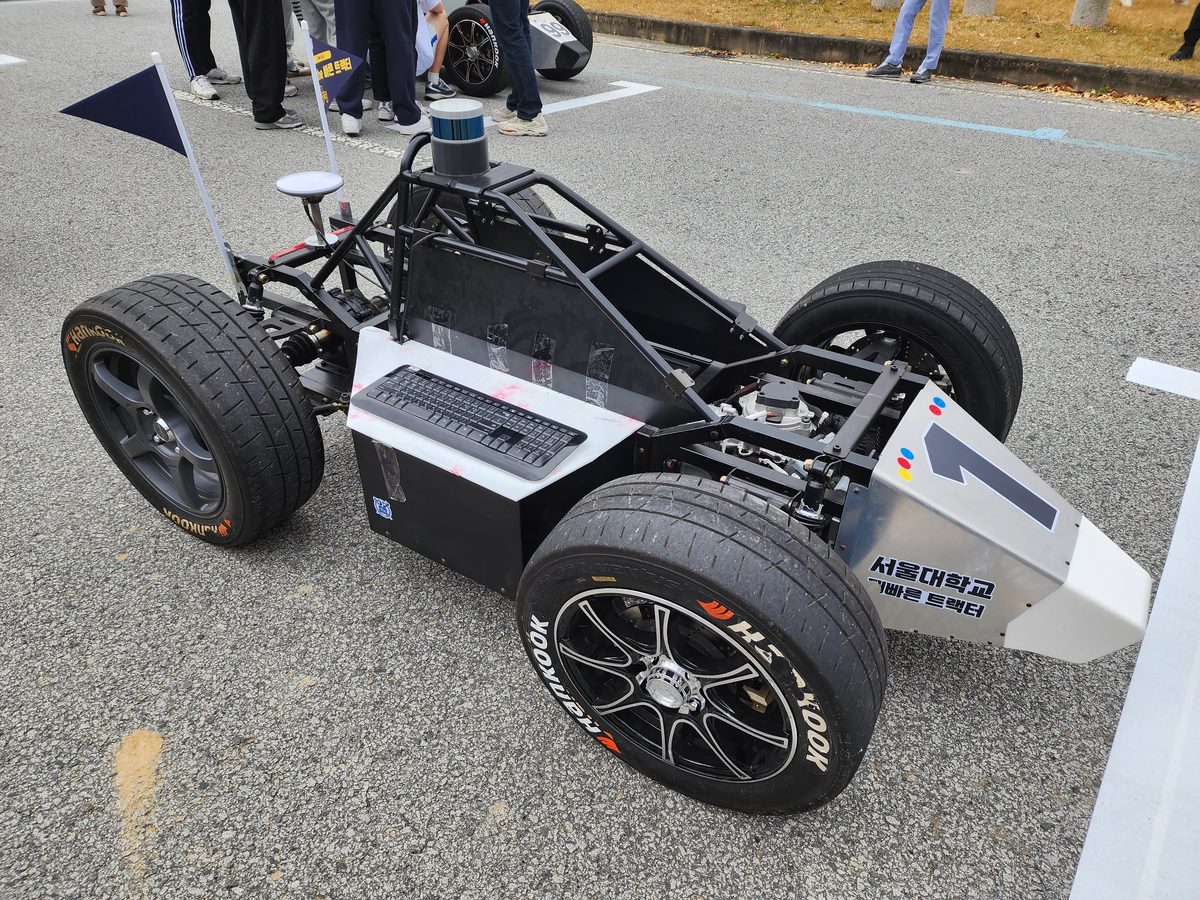
Robotics, 2022
An autonomous race car for Korea's first simultaneous-start self-driving race, with LiDAR avoidance, a custom perception data engine, and a lane-change state machine.
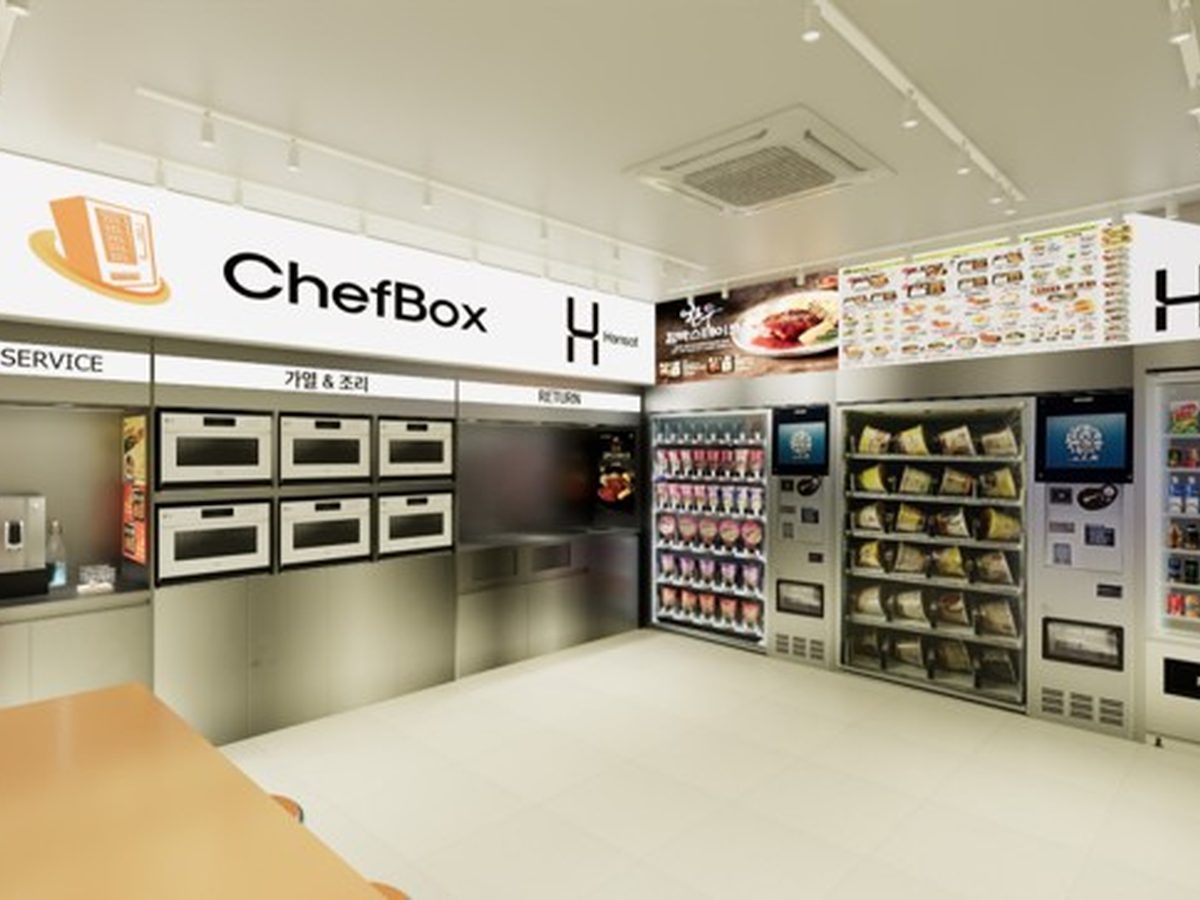
Product Excellence Award
Space-as-a-service for food retail. Subscription-based modular unmanned stores that lower the risk of franchise expansion.